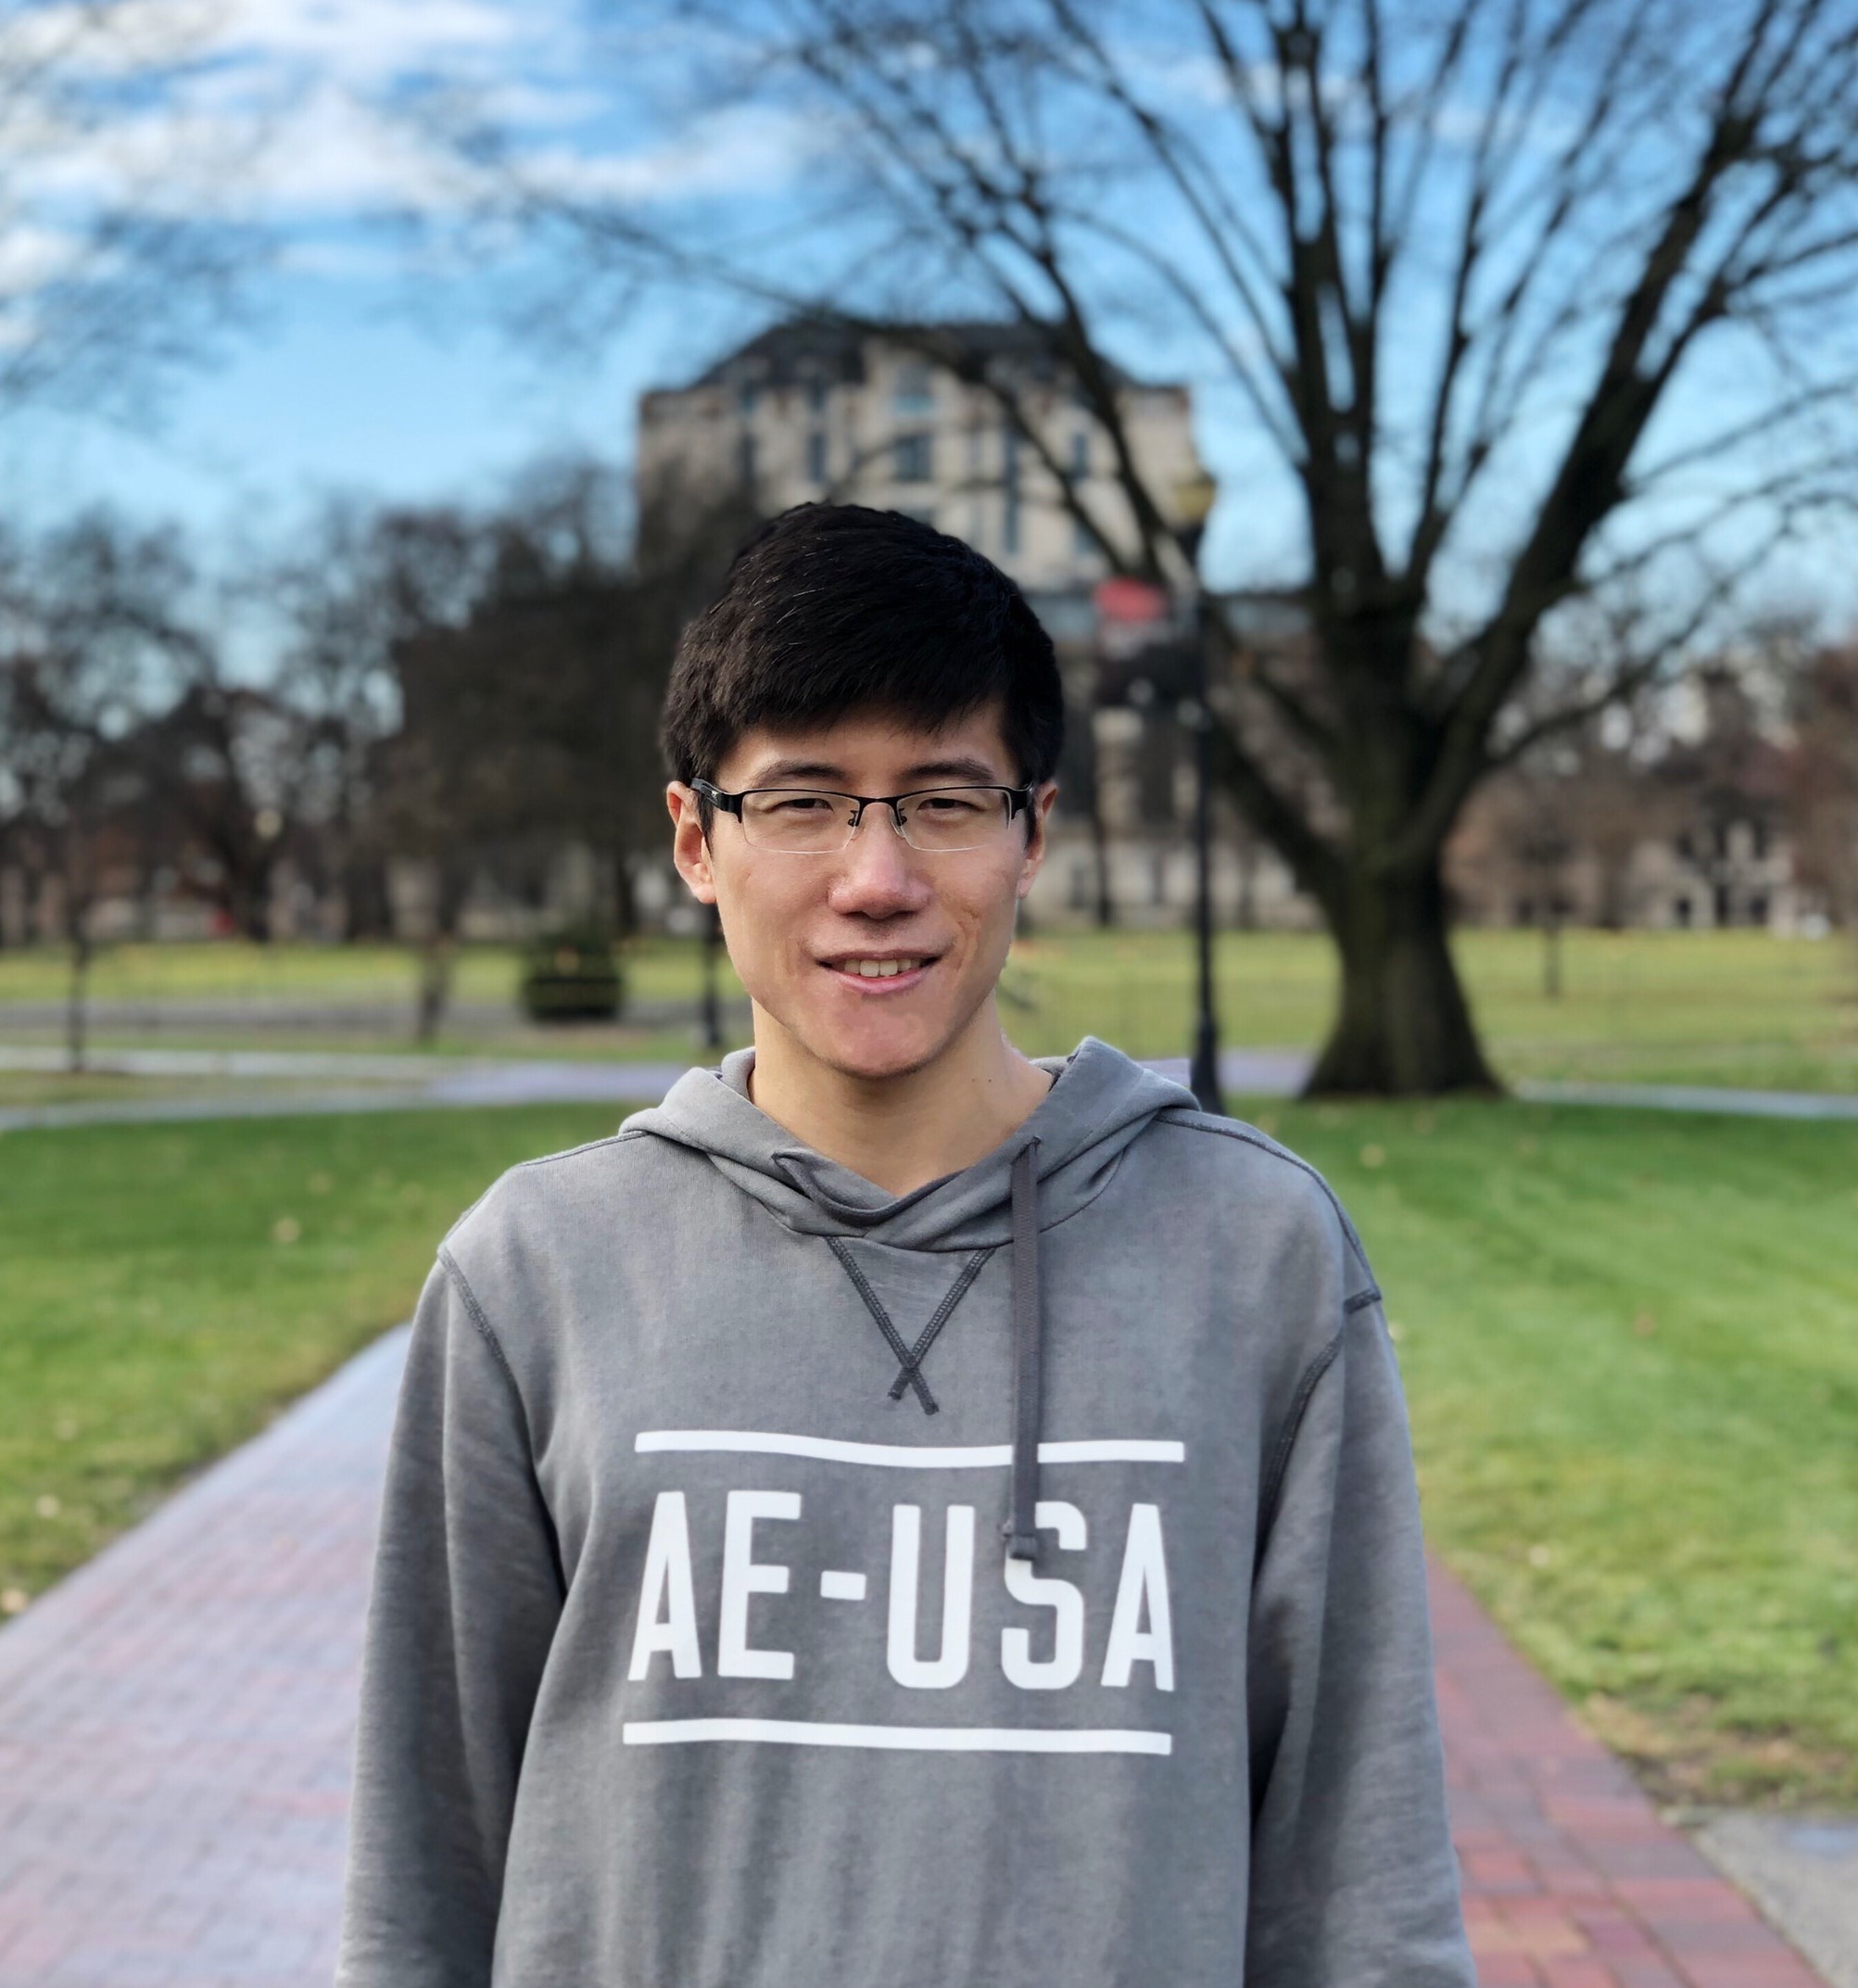
I am a Machine Learning Engineer at Torc Robotics, where I work on perception and geometry-centric learning systems for autonomous long-haul trucks. My current focus is camera-based localization, 3D geometric perception, and the large-scale deep learning systems that make autonomy safe and reliable.
Previously, I was a Research Scientist at Motorola Solutions, developing deep learning–based perception models for large-scale video surveillance and intelligent sensing platforms.
I received my Ph.D. in 2021 from the Photogrammetric Computer Vision Lab in the Department of Civil, Environmental and Geodetic Engineering at The Ohio State University, advised by Prof. Alper Yilmaz. During my Ph.D. I also earned a Graduate Minor in Computer Science (Artificial Intelligence Track) from the Department of Computer Science and Engineering.
Research interests
My research centers on computer vision and deep learning for geolocalization and 3D reconstruction, with a strong foundation in photogrammetry, multi-view geometry, and large-scale learning systems. Today I apply and extend these ideas to autonomous driving, working at the intersection of:
- Perception — detection, segmentation, multi-task learning, and multi-modal scene understanding
- Geometry — multi-view geometry, static multi-view keypoint detection, structure from motion, and 3D reconstruction
- Localization — visual odometry, and map-based and learning-based localization from camera and inertial sensors
- Systems — large-scale distributed training and evaluation, and serving deep models at scale